News
- Wrapped up my internship at MIRLE Automation.
- Joined the MediaTek MARC × NYCU research project on embodied AI, working with Prof. Yuan-Fu Yang.
- Our paper on complementary knowledge transfer via localized preference deltas was accepted to the AI for Math workshop @ ICML 2026!
- Started an internship at MIRLE Automation, building VLA applications for semiconductor robots.
- Presented my master's thesis, EA-KD, at ICCV 2025 in Honolulu!
- Started as an Invited Scientist at the Technical University of Munich, working with Prof. Zeynep Akata.
Selected Publications
EA-KD: Entropy-Based Adaptive Knowledge Distillation
Improves knowledge transfer across vision and language modalities by prioritizing valuable training samples.
Learning from One Another: Toward Complementary Knowledge Transfer via Localized Preference Deltas
Enables complementary knowledge transfer among LLMs of different scales through localized preference differences.
Robo4D: Robot Demonstrations are Free 4D Supervision for VLM and VLA
Turns robot demonstrations into annotation-free 4D VQA supervision, improving Qwen3-VL-2B by 12.5 pp on VLM4D (40.1% → 52.6%) and downstream VLA success by up to 7.6 pp on SimplerEnv-Bridge.
Learning Visual Contact Representations from Triboelectric Signals for Tactile-Free Robot Manipulation
Learns visual contact representations from triboelectric (TENG) tactile signals during training, so a camera-only VLA can reason about contact: +9.4 pp interaction QA accuracy and sorting success from 55.0% to 66.3%.
Reference-Free Rating of LLM Responses via Latent Information
Uses internal model signals for deterministic, fine-grained, reference-free LLM evaluation and ranking.
Deep Learning-Based Computer-Aided Diagnosis of Rheumatoid Arthritis with Hand X-Ray Images
A YOLO-based joint detection and severity classification for rheumatoid arthritis assessment from hand X-rays.
Experience
Research Assistant · MediaTek Advanced Research Center (MARC) × NYCU
Project: Toward Scalable Precision Embodied AI: From Spatial Perception to Spatiotemporal VLA for Edge Intelligence. I work on two fronts: improving the spatiotemporal understanding of VLMs and VLAs, which led to Robo4D (see Publications), and running VLA inference on MediaTek's on-device NPU, an ongoing effort toward deploying robot policies at the edge. I also mentor two master's students on the project.
Research Assistant · NSTC Research Project
Project: Generative AI for Cross-Domain Robot Applications, on bimanual manipulation for logistics automation. Deployed an end-to-end VLA system on the OpenArm v2 bimanual robot for autonomous sorting, reaching 83% success on standard tasks and 65% on unseen objects in real-world trials. I also mentor one master's student.
Embodied AI Intern · MIRLE Automation
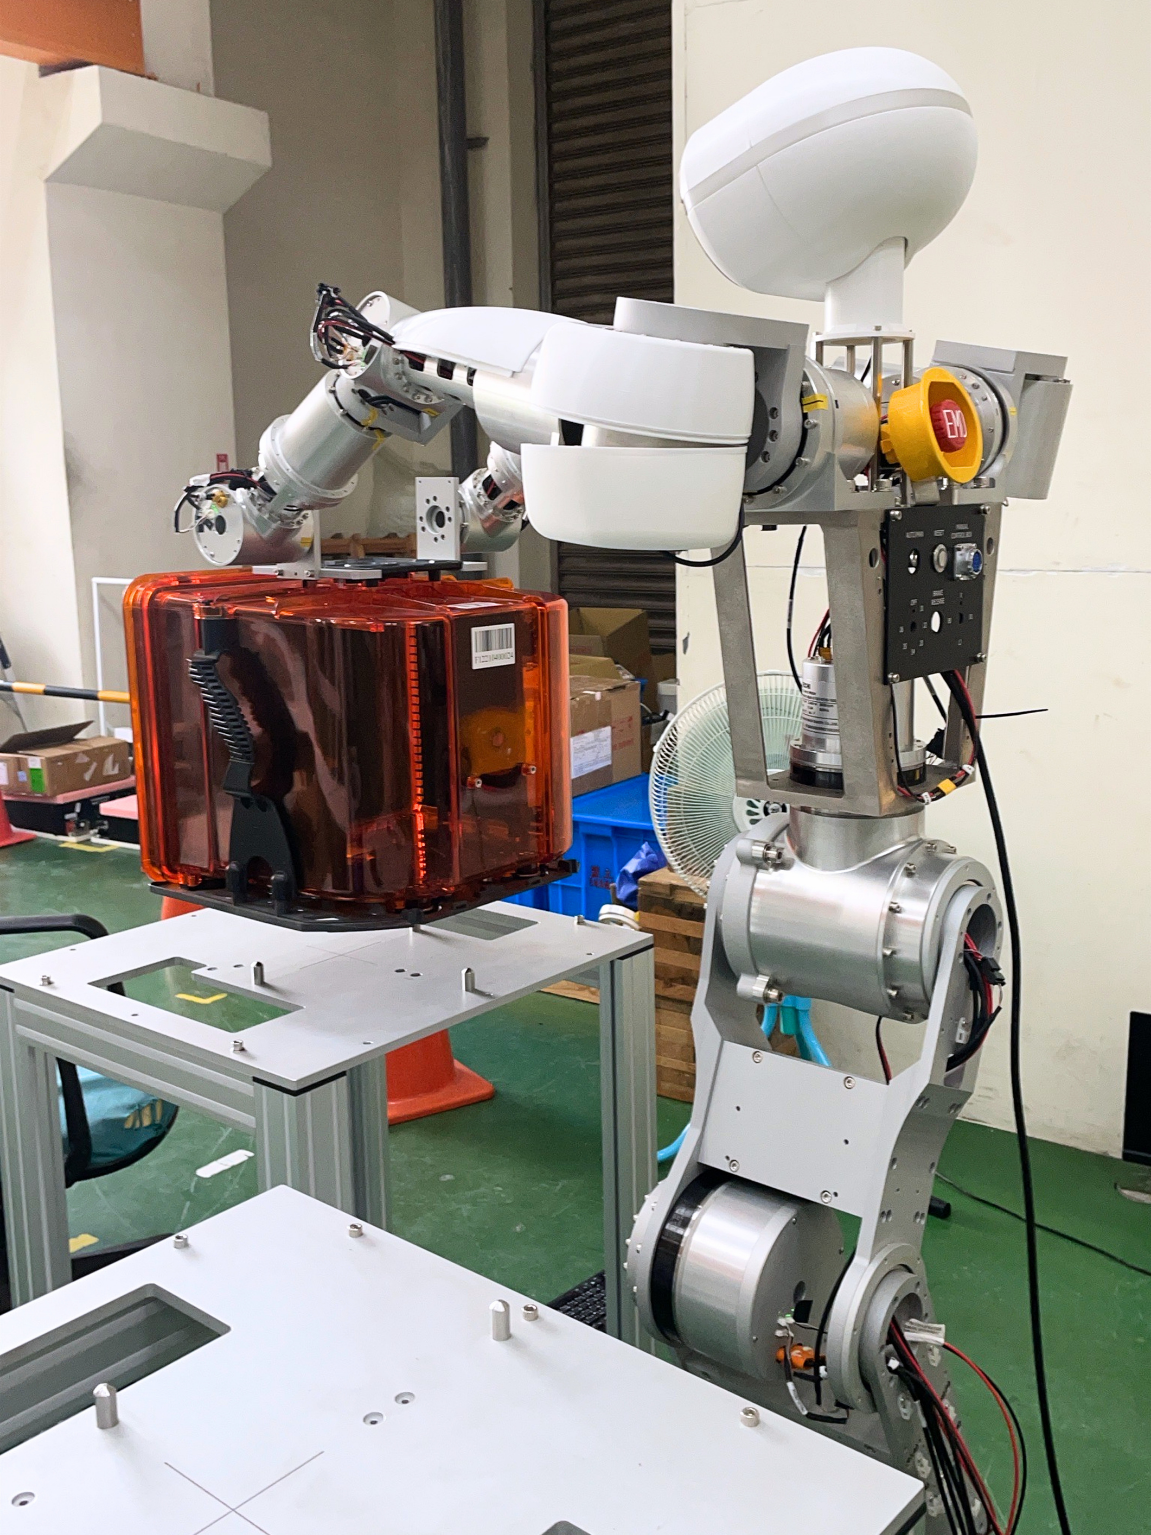
Developed proof-of-concept VLA applications for semiconductor AMHS (FOUP transport, wafer cassette loading); built end-to-end pipelines spanning teleoperation, model fine-tuning, and deployment from simulation to real-world environments.
Invited Scientist · Technical University of Munich
Collaborated remotely with Prof. Zeynep Akata on LLM distillation and LLM-as-a-Judge evaluation.
Education
M.B.A., Institute of Management of Technology · National Yang Ming Chiao Tung University
Thesis: Entropy-Based Adaptive Knowledge Distillation (ICCV 2025) · Academic Excellence Award (2024)